
Welcome!
I am a second-year Ph.D. student at University of California San Diego (UCSD), advised by Prof. Biwei Huang. I am also working at Aether AI, where I lead the robotics group. During my undergraduate studies, I was a Visiting Researcher at the Berkeley NLP Group, working with Prof. Alane Suhr.
My research focuses on robot foundation models, embodied agents, and world simulation. Currently, I am working on building robot intelligence systems (e.g., CRIS-0), as well as developing realistic world simulations (e.g., SimWorld) for agent training. In the long term, my goal is to build general-purpose embodied intelligence that can autonomously learn, reason, and act in the physical world, generalizing across embodiments and tasks from only a few demonstrations.
You can find my CV here. I am always open to any form of collaboration. If you have any ideas for potential collaboration, or just feel like having a casual chat, please feel free to reach out!
🔥 News
- 2026.07: Our work DeliveryBench has been accepted to COLM 2026.
- 2026.03: Joined Aether AI to lead the robotics group.
- 2025.04: Thrilled to join UCSD as a Ph.D. student. Looking forward to starting this new journey!🌴🌊☀️
- 2025.02: Our work on evaluating VLMs on photorealistic color illusion scenes has been accepted to CVPR 2025.
- 2024.09: Our work on multi-perspective communication has been accepted by EMNLP main 2024.
- 2024.09: Our work on multimodal instruction-tuning for biomedicine has been accepted to NeurIPS D&B 2024!
📝 Publications

DeliveryBench: Can Agents Earn Profit in Real World?
Lingjun Mao, Jiawei Ren, Kun Zhou, Jixuan Chen, Ziqiao Ma, Lianhui Qin†
COLM 2026
- We present DeliveryBench, a realistic embodied benchmark for food delivery that evaluates long-horizon, constraint-rich decision-making to maximize net profit over hours.

SimWorld: An Open-ended Realistic Simulator for Autonomous Agents in Physical and Social Worlds
Jiawei Ren, Yan Zhuang, Xiaokang Ye*, Lingjun Mao, Xuhong He, Jianzhi Shen, …, Tianmin Shu†, Zhiting Hu†, Lianhui Qin†
Technical Report
- We propose SimWorld Simulator, featuring three key designs: (1) realistic, open-ended world simulation, (2) rich interface for LLM/VLM agents, and (3) diverse physical and social reasoning scenarios

Evaluating Model Perception of Color Illusions in Photorealistic Scenes
Lingjun Mao, Zineng Tang, Alane Suhr
CVPR 2025
- We propose an automated framework for generating realistic color illusion images, build a large-scale dataset (RCID), and systematically investigate the underlying mechanisms by which VLMs are misled by color illusions.

Grounding Language in Multi-Perspective Referential Communication
Zineng Tang, Lingjun Mao, Alane Suhr
EMNLP main 2024
- We introduce a task and dataset for referring expression generation and comprehension in multi-agent embodied environments.

Biomedical Visual Instruction Tuning with Clinician Preference Alignment
Hejie Cui*, Lingjun Mao*, Xin Liang, Jieyu Zhang, Hui Ren, Quanzheng Li, Xiang Li, Carl Yang
NeurIPS 2024
- we propose a data-centric framework (Biomed-VITAl) that incorporates clinician preferences into both stages of generating and selecting instruction data for tuning biomedical multimodal foundation models.
📰 Blog
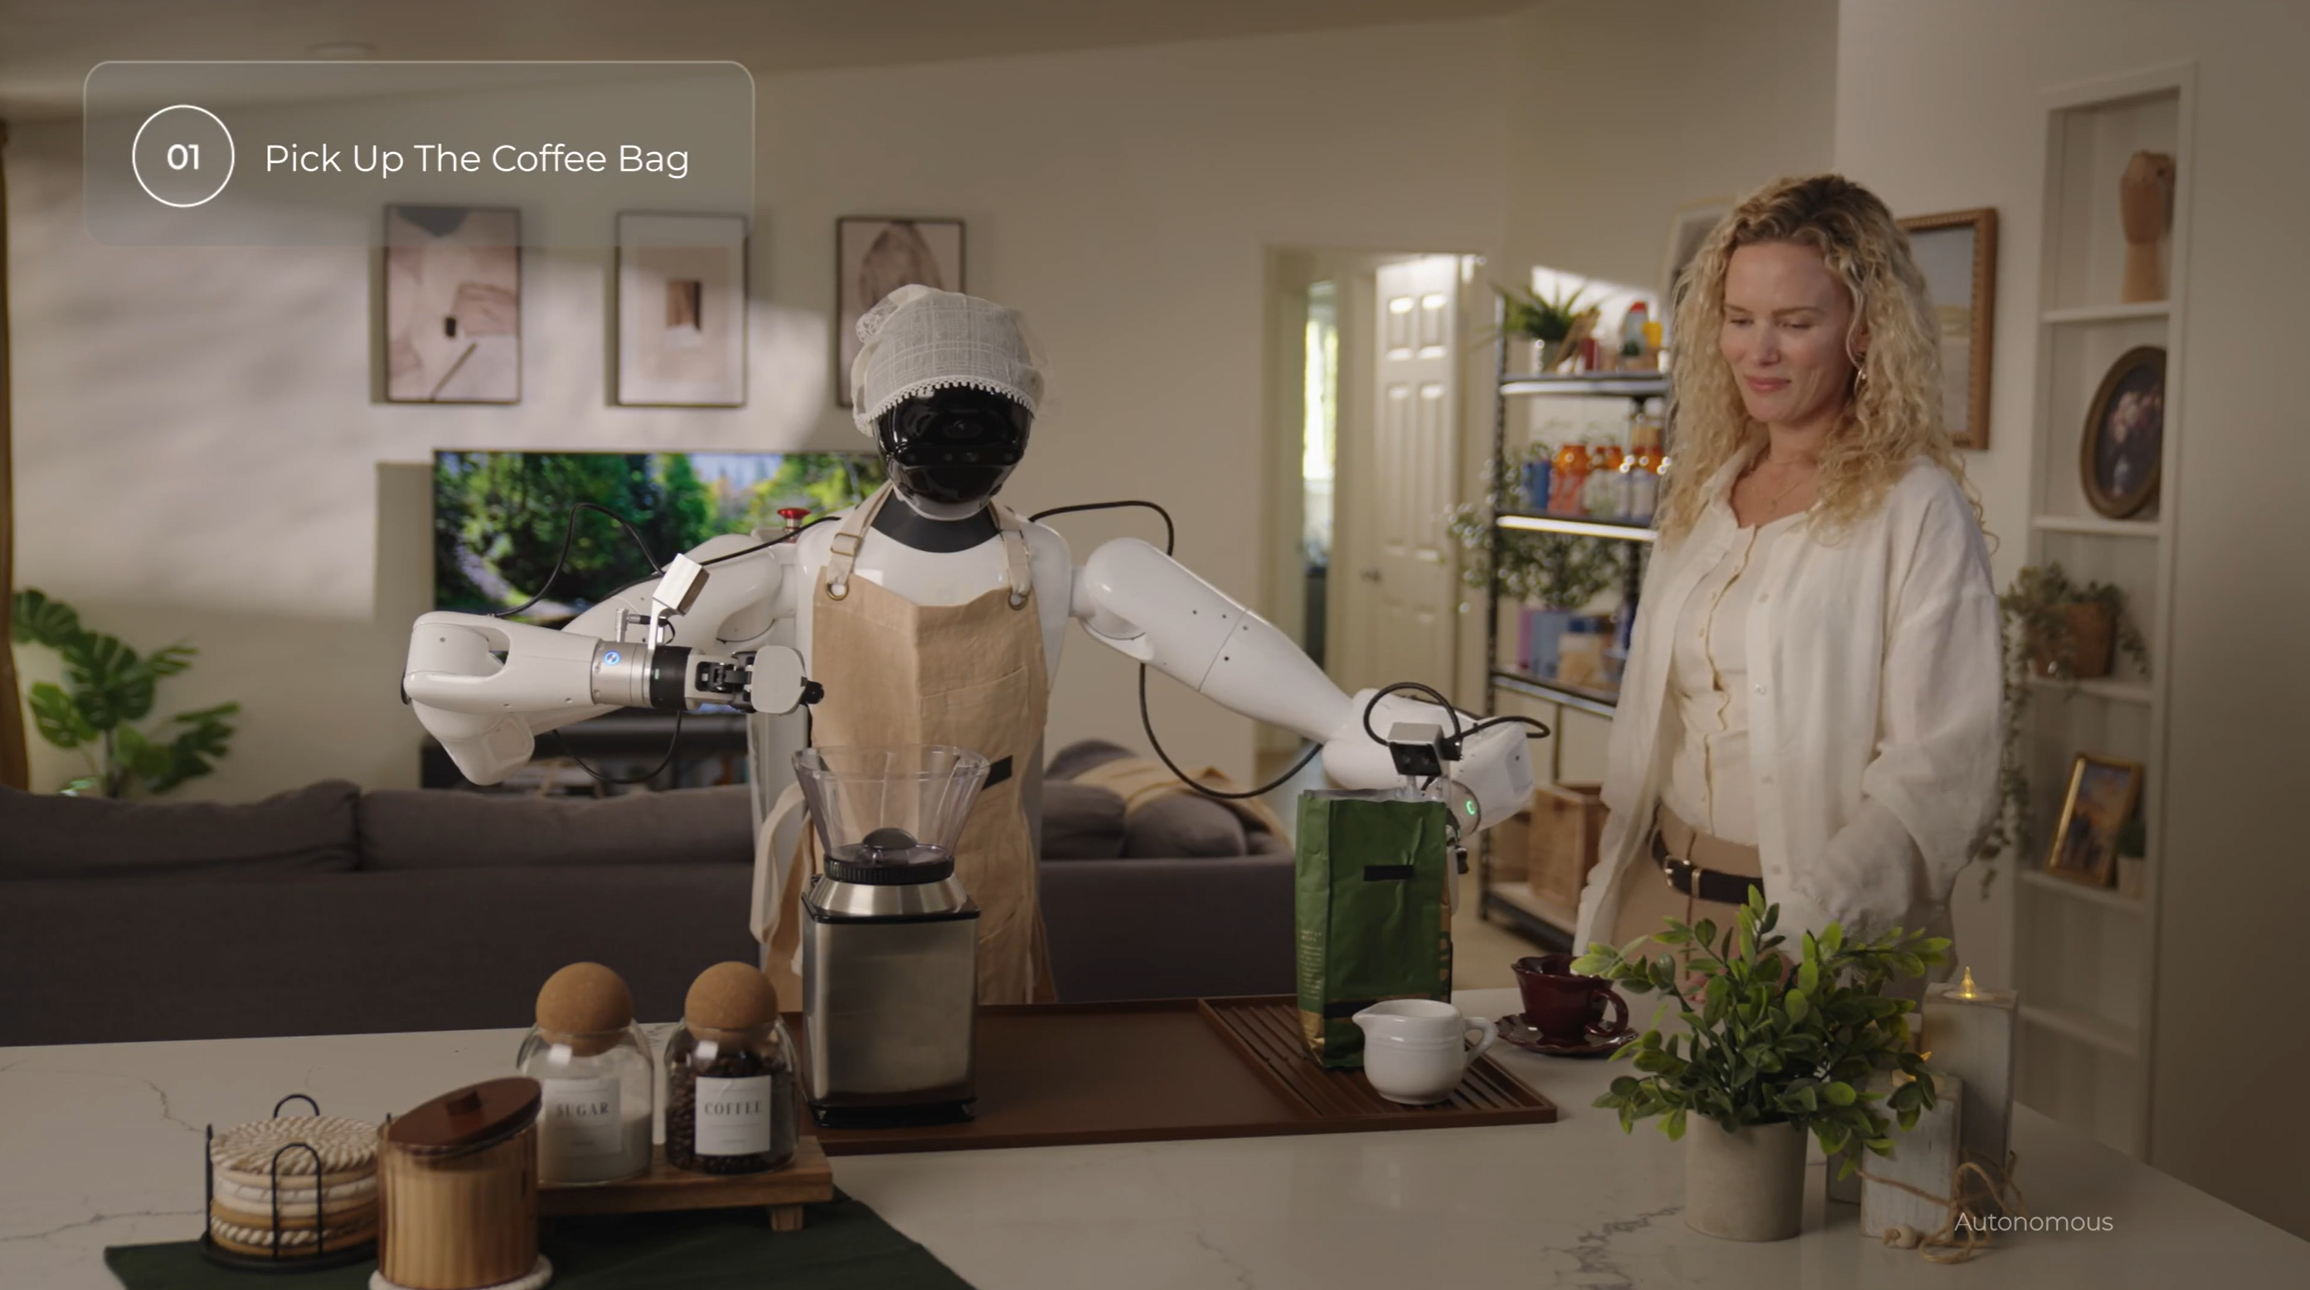
Building a Real-world Autonomous Robotic System with Causality-driven Agent and World Model
Lingjun Mao†, Lukun He†, Jinglin Cao†, Wenpeng Xu†, …, Kun Zhou*, Biwei Huang
Aether AI, 2026
- CRIS-0 is a causality-driven robotic intelligence system that integrates a Causal Agent with a Causal World Model to construct structured causal representations of the physical world, enabling robots to actively explore, intervene in, reason about, and adapt to their environments.
📖 Educations
- 2024.09 - 2024.10, Visiting Student in University of California, Berkeley, USA
- 2020.09 - 2025.7, Software Engineering (GPA: 4.0/4.0), Tongji University, Shanghai, China
2026@Lingjun Mao